Welcome to the introduction to my RC ROV project.
This is not my first try at a RC submarine. In fact it was one of my first projects about 8 years ago(the ESC lasted about 5 seconds and thus ended my submarine adventures). A couple years ago I got into FPV drones. This was a lot of fun and more successful, however there was only so much you can do. ROVs on the other hand have endless possibilities and pose a significantly higher engineering challenge(and as bonus if they fail they wont fall on anyone or catch a field on fire!)
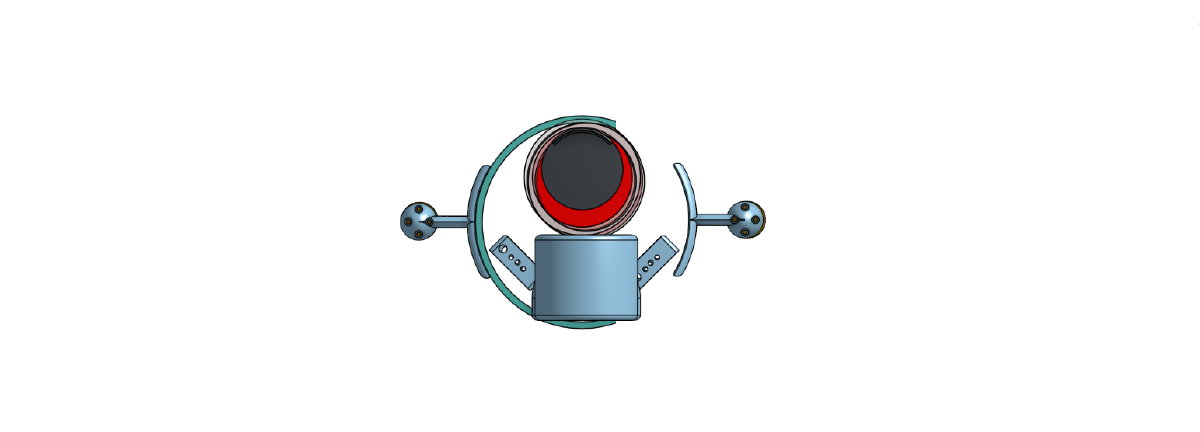
For this ROV I am going for a tether controlled, deep diving approach. The ROV will employ a combination of sealed air compartments and epoxy potted parts. The Sub will carry its own battery, have 3 water cooled ESCs and will communicate both video and control signals to the surface via tether.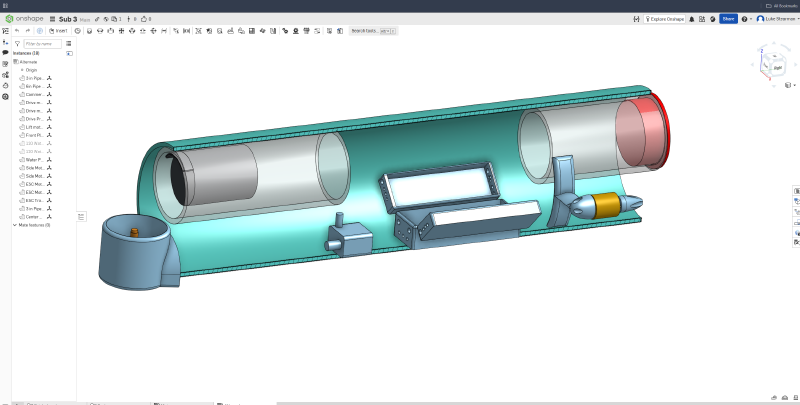
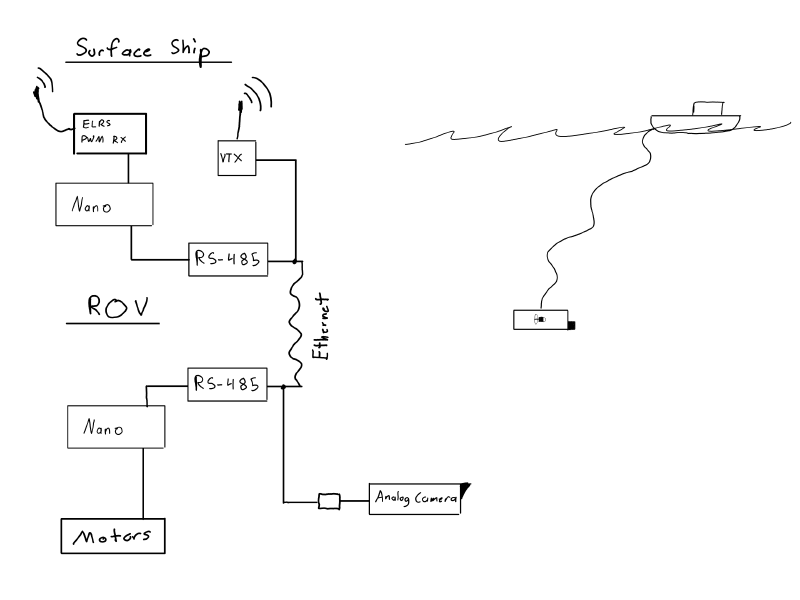
There are some downsides to a tether, it has limited range and can get tangled on things near the shore. To help negate this the ROV will be tethered to Explorer 1 my surface ship, from there it will be able to be controlled with the same controller as the ship and transmit its video wirelessly. This means it operates flawlessly with RC drone/plane equipment and the sub can be taken out to the diving area without a long cable from the shore.