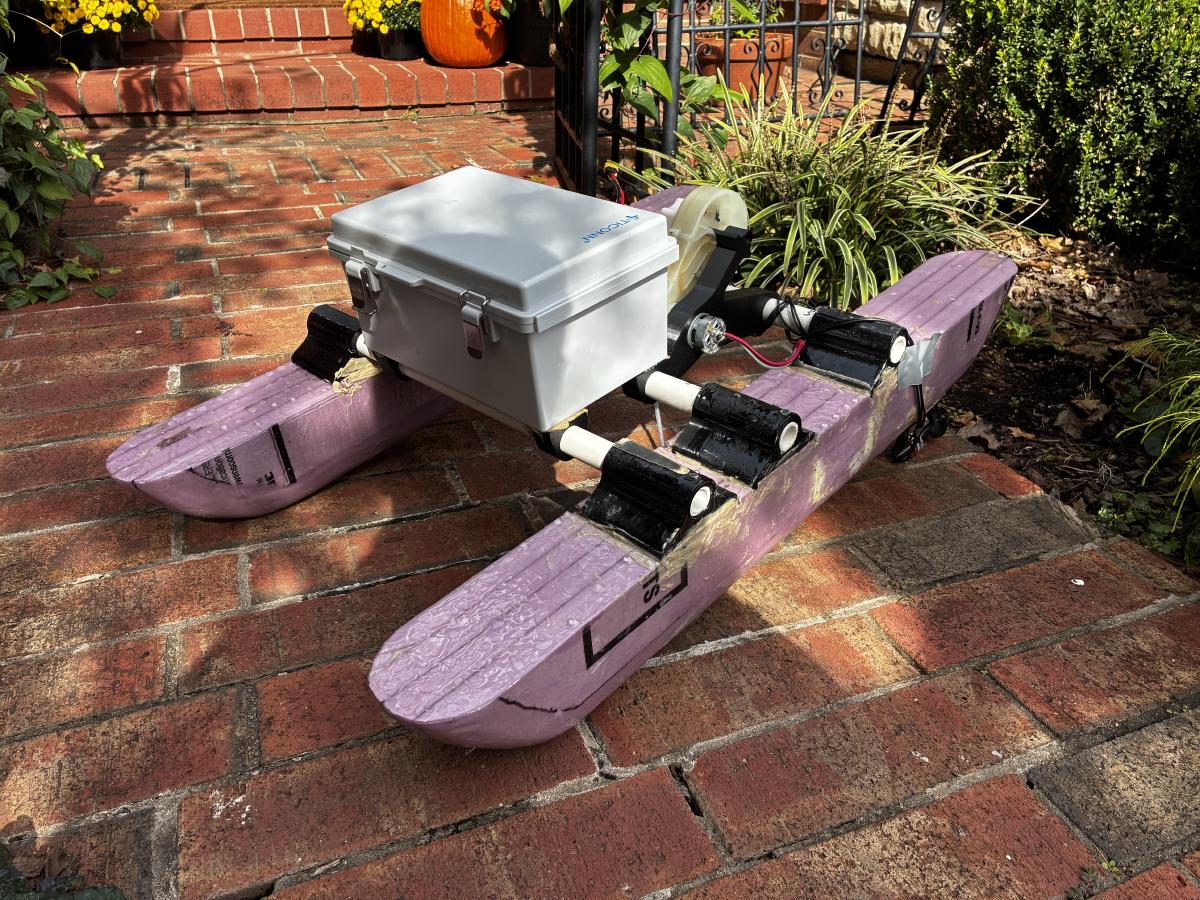
This is Explorer 1. My surface ship for all things ROV. It will serve as a platform for depth testing individual parts, it will be what the sub will be tethered to during operation and may be able to assist in rescue operations!
It is a catamaran style ship with differential steering, water cooled ESCs and the receiver/ video transmitter can control both itself and the attached ROV.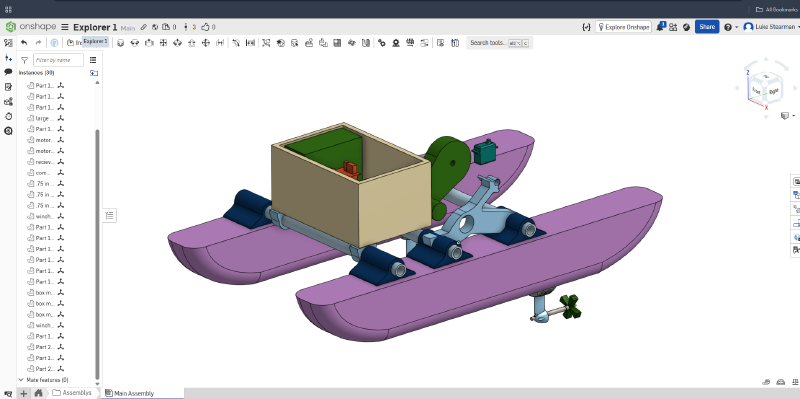
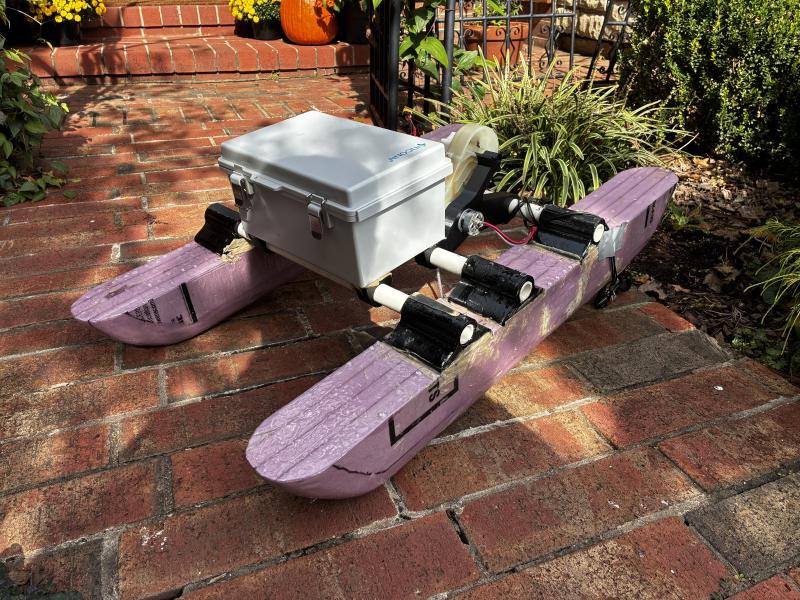
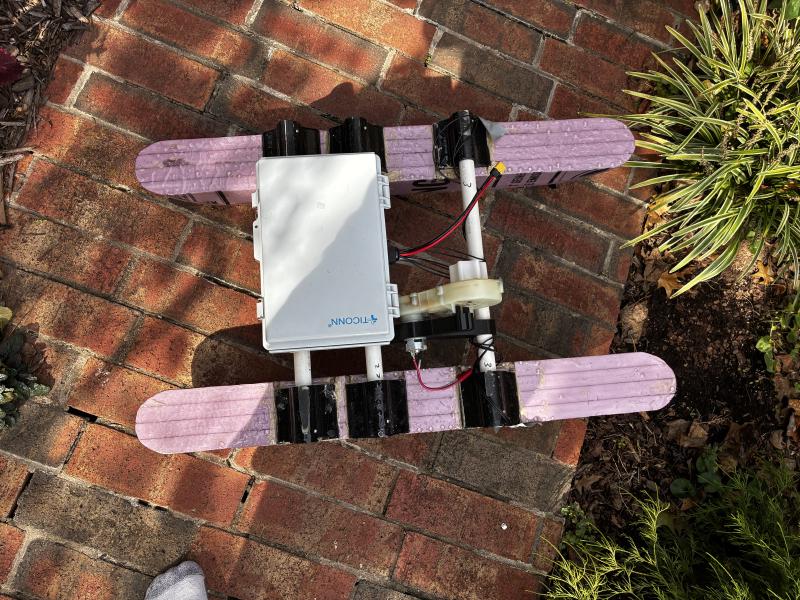
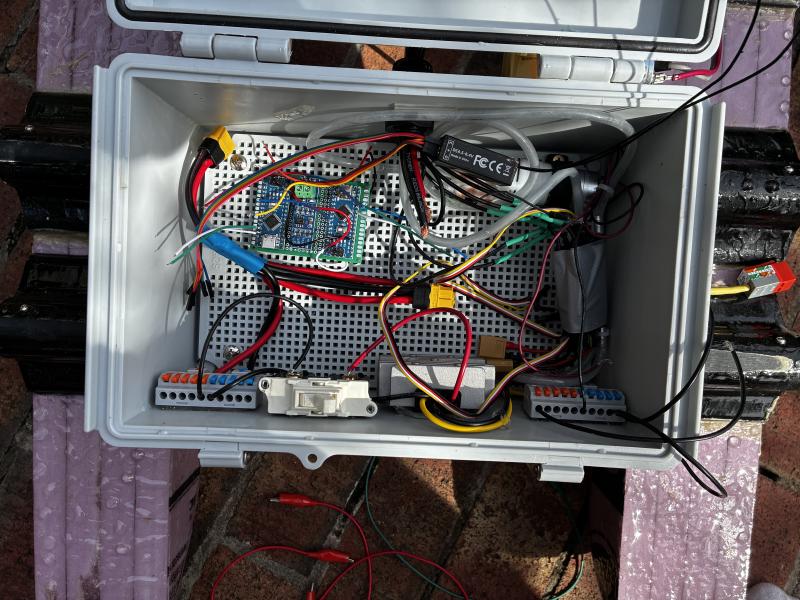
This is still a work in progress. It has had a successful maiden voyage to confirm the steering and water cooling systems work. The next step will be fitting on the tether and wiring it to the ROV.